Deep Robotics Lite3 LiDAR
Overview
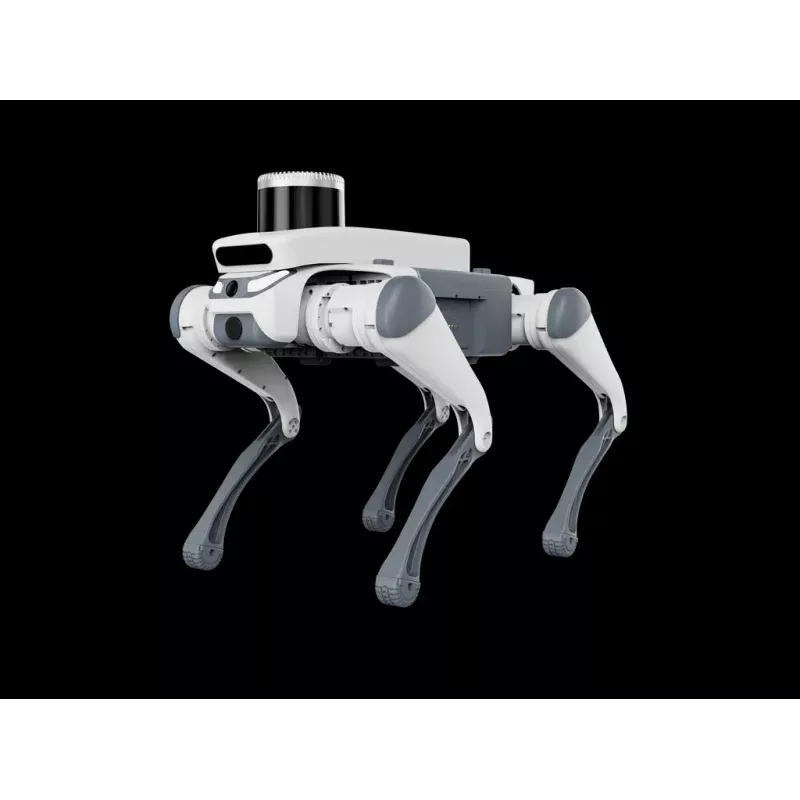
The Deep Robotics Lite3 LiDAR is the autonomous-navigation tier of the Lite3 line. It pairs the series’ agile locomotion with a complete onboard perception stack: a wide-angle camera, dual ultrasonic radars, an Intel RealSense D435i depth camera, a LiDAR module, and an NVIDIA Jetson Xavier NX AI computer. It is built for autonomous-navigation, mapping, and perception research and development.
Beyond the obstacle auto-stop, visual following, and forward obstacle avoidance found on the Pro, the LiDAR edition adds an Auto Mode for autonomous navigation, a LiDAR-exclusive capability run through Deep Robotics’ perception development resources. A Livox or Leishen LiDAR module enables 3D mapping, with Faster-LIO SLAM and the Nav2 navigation stack pre-configured. It uses Flat, RUG, Grip, and H-Step gaits across slopes, grass, and uneven steps.
It climbs 40 degree slopes and steps up to 15 cm, or up to 18 cm in AI Motion Mode, carries a 2.5 kg payload, and runs 1.5 to 2 hours with about 2.7 km of range. The standing height with LiDAR is 496 mm and weight is 13.5 kg. The LiDAR edition runs Ubuntu 20.04 with ROS1 and ROS2 and provides open SDK and API access. It is rated for 0 to 40 degrees Celsius indoor and controlled outdoor use.
Specifications
| Configuration | |
|---|---|
| Dimensions (Standing, with LiDAR) | 610 x 370 x 496 mm |
| Weight | 13.5 kg (including battery and LiDAR) |
| Rated Payload | 2.5 kg |
| Max Range | 2.7 km (LiDAR-equipped configuration) |
| Perception Host | NVIDIA Jetson Xavier NX |
| LiDAR | Livox or Leishen LiDAR module for 3D mapping |
| Depth Camera | Intel RealSense D435i |
| Additional Sensors | Wide-angle camera; dual ultrasonic radars |
| Autonomy | Forward obstacle avoidance; Auto Mode for autonomous navigation (LiDAR-exclusive) |
| SLAM and Navigation | Faster-LIO SLAM and Nav2 navigation stack, pre-configured |
| Locomotion | |
| Degrees of Freedom | 12 (3 joints per leg) |
| Max Speed | 2.5 m/s |
| Max Slope | 40 degrees |
| Max Step Height | 15 cm standard; up to 18 cm in AI Motion Mode |
| Joint Torque | 50 percent higher than the previous generation |
| Self-Recovery | Automatic righting after a fall |
| Power and Endurance | |
| Endurance | 1.5 to 2 hours continuous operation |
| Battery | Hot-swappable, quick-release |
| Operating Temperature | 0 to 40 degrees C (indoor and controlled outdoor) |
| Overtemperature Protection | Stops and lies down if motors overheat |
| Computing and Development | |
| Motion Host | RK3588 ARM processor |
| Control Frequency | Up to 1 kHz |
| IMU | 9-axis inertial measurement unit |
| Operating System | Ubuntu 20.04 |
| ROS Support | ROS1 (Noetic) and ROS2 (Foxy) |
| Development Access | Open SDK and API (C++ and Python); Motion SDK |
Key Features
- Autonomous Navigation: A LiDAR-exclusive Auto Mode enables autonomous navigation, with Faster-LIO SLAM and the Nav2 stack pre-configured.
- 3D Mapping: A Livox or Leishen LiDAR module, combined with the RealSense depth camera, supports 3D mapping, localization, and environmental reconstruction.
- Full Perception Stack: Wide-angle camera, dual ultrasonic radars, depth camera, LiDAR, and an NVIDIA Jetson Xavier NX AI computer.
- Forward Obstacle Avoidance: Detects and routes around obstacles in its path, in addition to obstacle auto-stop and visual following.
- Multi-Terrain Gaits: Flat, RUG, Grip, and H-Step gaits handle slopes, grass, and uneven steps; steps up to 18 cm in AI Motion Mode.
- Open Development Stack: Ubuntu 20.04 with ROS1 and ROS2, plus open SDK and API access for navigation and mapping research.
Applications
The Lite3 LiDAR suits labs and developers working on autonomous navigation and mapping with a legged platform: LiDAR SLAM, path planning with Nav2, and perception research in GPS-denied or unstructured indoor environments. With its LiDAR, depth camera, and Jetson compute, it is the most capable perception configuration in the Lite3 line.
It is designed for indoor and controlled outdoor use, rated for 0 to 40 degrees Celsius, and is not weatherproof, so it is not intended for harsh industrial field deployment like the IP-rated X-series. Because the LiDAR and sensor package add weight, its rated payload (2.5 kg) and range (about 2.7 km) are lower than the lighter configurations.
Setup and Getting Started
- Unbox and inspect: Remove the robot, LiDAR, and sensor package and check for shipping damage.
- Charge the battery: Charge the hot-swappable battery fully before first use.
- Power on and pair the controller: Power the robot and pair the included gamepad controller.
- Connect to the perception host: Access the Jetson Xavier NX and confirm the LiDAR, depth camera, and cameras are detected, following the user manual.
- Run mapping and navigation: Launch the pre-configured Faster-LIO SLAM and Nav2 examples, and build a map of a test area.
- Test Auto Mode safely: Validate autonomous navigation in a clear, mapped area within the rated limits.
What’s Included
- Robot Unit: Deep Robotics Lite3 LiDAR quadruped with full perception stack and pre-installed firmware (x1)
- Perception Stack: LiDAR module, NVIDIA Jetson Xavier NX, Intel RealSense D435i, wide-angle camera, dual ultrasonic radars (installed)
- Battery Pack: Rechargeable hot-swappable battery (x1)
- Charger: AC power adapter with regional plug (x1)
- Controller: Wireless gamepad controller (x1)
- Documentation: Quick-start guide, safety manual, and SDK, perception, and navigation references
Documentation and Resources
- Lite3 AI User Manual (PDF): Download
- Developer Resources (SDK and examples): github.com/DeepRoboticsLab
Warranty Information
The Lite3 LiDAR is covered by the following limited warranty. RoboticsSelect is an authorized Deep Robotics dealer, so warranty support is handled through us.
| Coverage | Details |
|---|---|
| Electronics | 1 year from the date of delivery |
| Joints, Legs, and Battery | 6 months; reduced to 3 months once AI Motion Mode is unlocked |
Not Covered
- Shell and accessories
- Damage from misuse, negligence, or unauthorized modification
- Normal wear and tear on consumable components
- Damage from use outside recommended operating conditions, or unauthorized repair or disassembly
All warranty claims require valid proof of purchase. Regional terms may vary.